Precision Feedback
Integrated sensing of position, force, pressure and temperature for accurate, real-time monitoring and control.
Actuators
Servo Instrumented Cylinder
Bring hydraulic actuation into your control architecture with a cylinder that combines sensing, servo control and communication. The SIC reduces the integration work between mechanics, hydraulics and embedded electronics.
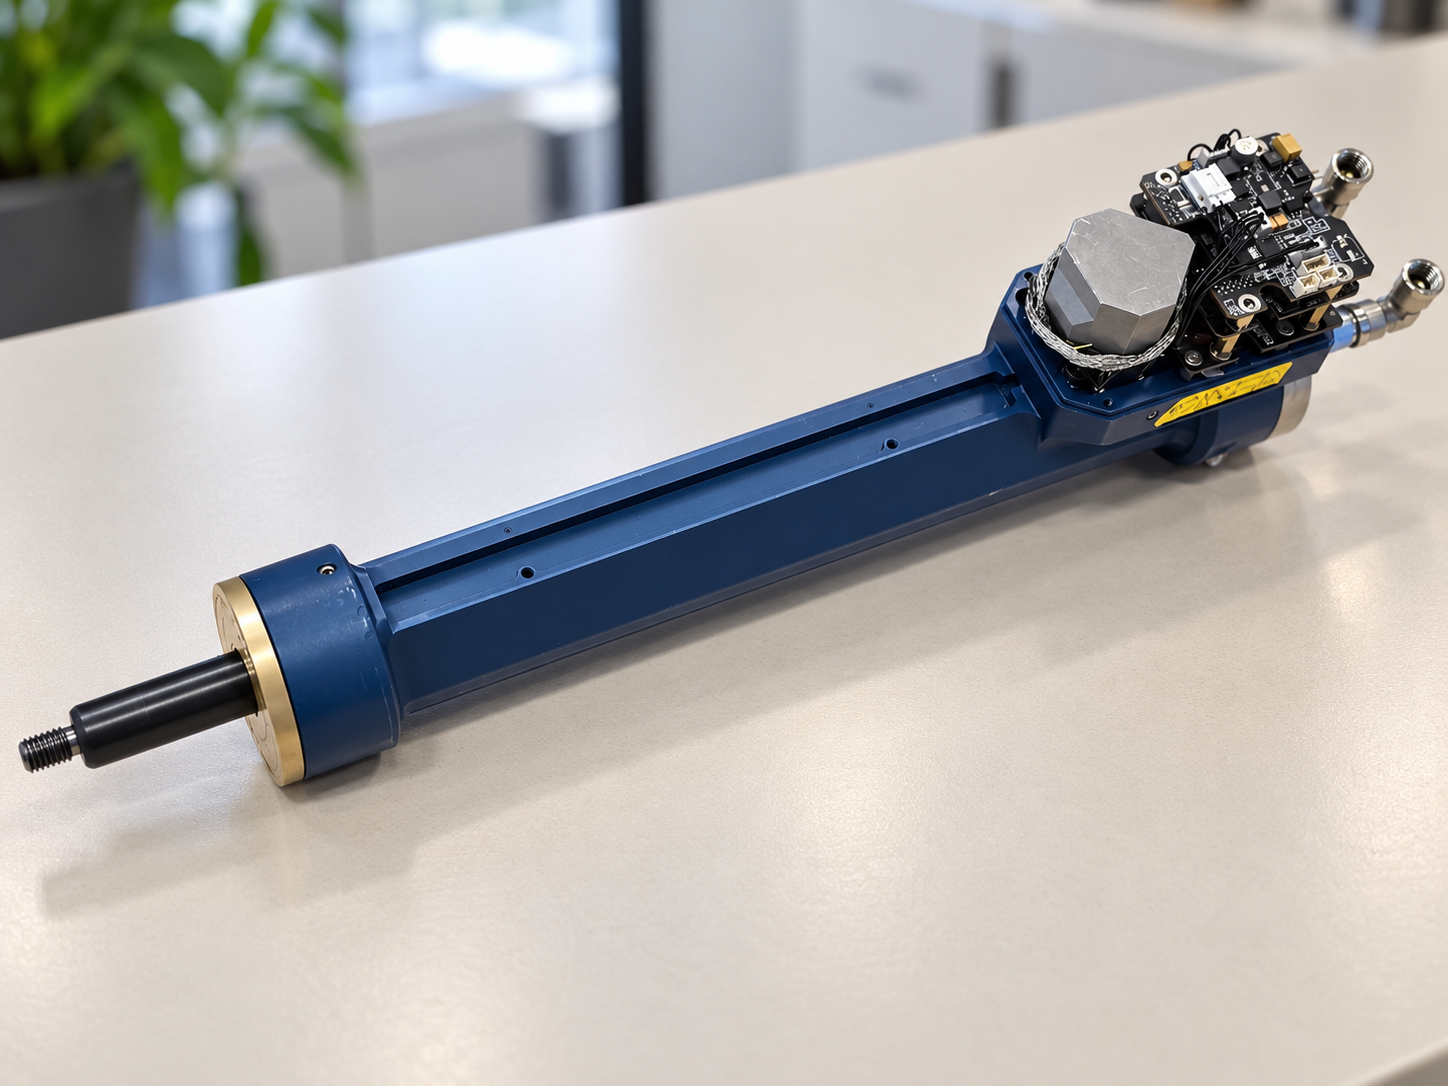
Integrated sensing of position, force, pressure and temperature for accurate, real-time monitoring and control.
Dedicated electronics and EtherCAT communication for precise, responsive hydraulic actuation.
ROS 2 compatibility for streamlined motion control, monitoring and data acquisition.
Contact us to discuss your application and find the configuration best suited to your technical requirements.
| Model | Bore (mm) | Rod (mm) | Max. stroke (mm) | Extension stall force at 210 bar (kN) | Pin-to-pin length (mm) |
|---|---|---|---|---|---|
| SIC-18-40-A | 40 | 18 | 255 | 25.75 | 740 |
| SIC-18-40-S | 40 | 18 | 250 | 20.5 | 480 |
| SIC-18-30-A | 30 | 18 | 260 | 14.45 | 460 |
| SIC-18-30-S | 30 | 18 | 260 | 9 | 740 |
| SIC-18-25-A | 25 | 18 | 260 | 9.75 | 460 |
| SIC-18-25-S | 25 | 18 | 260 | 4.65 | 740 |
| SIC-12-25-S | 25 | 12 | 260 | 10 | 740 |
| SIC-12-25-A | 25 | 12 | 260 | 7.6 | 445 |
| SIC-12-15-S | 15 | 12 | 245 | 1.1 | 745 |
| SIC-12-15-A | 15 | 12 | 250 | 3.5 | 745 |
A customer-selected, two-stage servovalve is driven through dedicated electronics with an EtherCAT connection.
Explore the SIC Electronic BoardFor robotic and mechatronic projects that need force, actuator feedback and coordinated motion.
Discuss Your ApplicationComplete the architecture
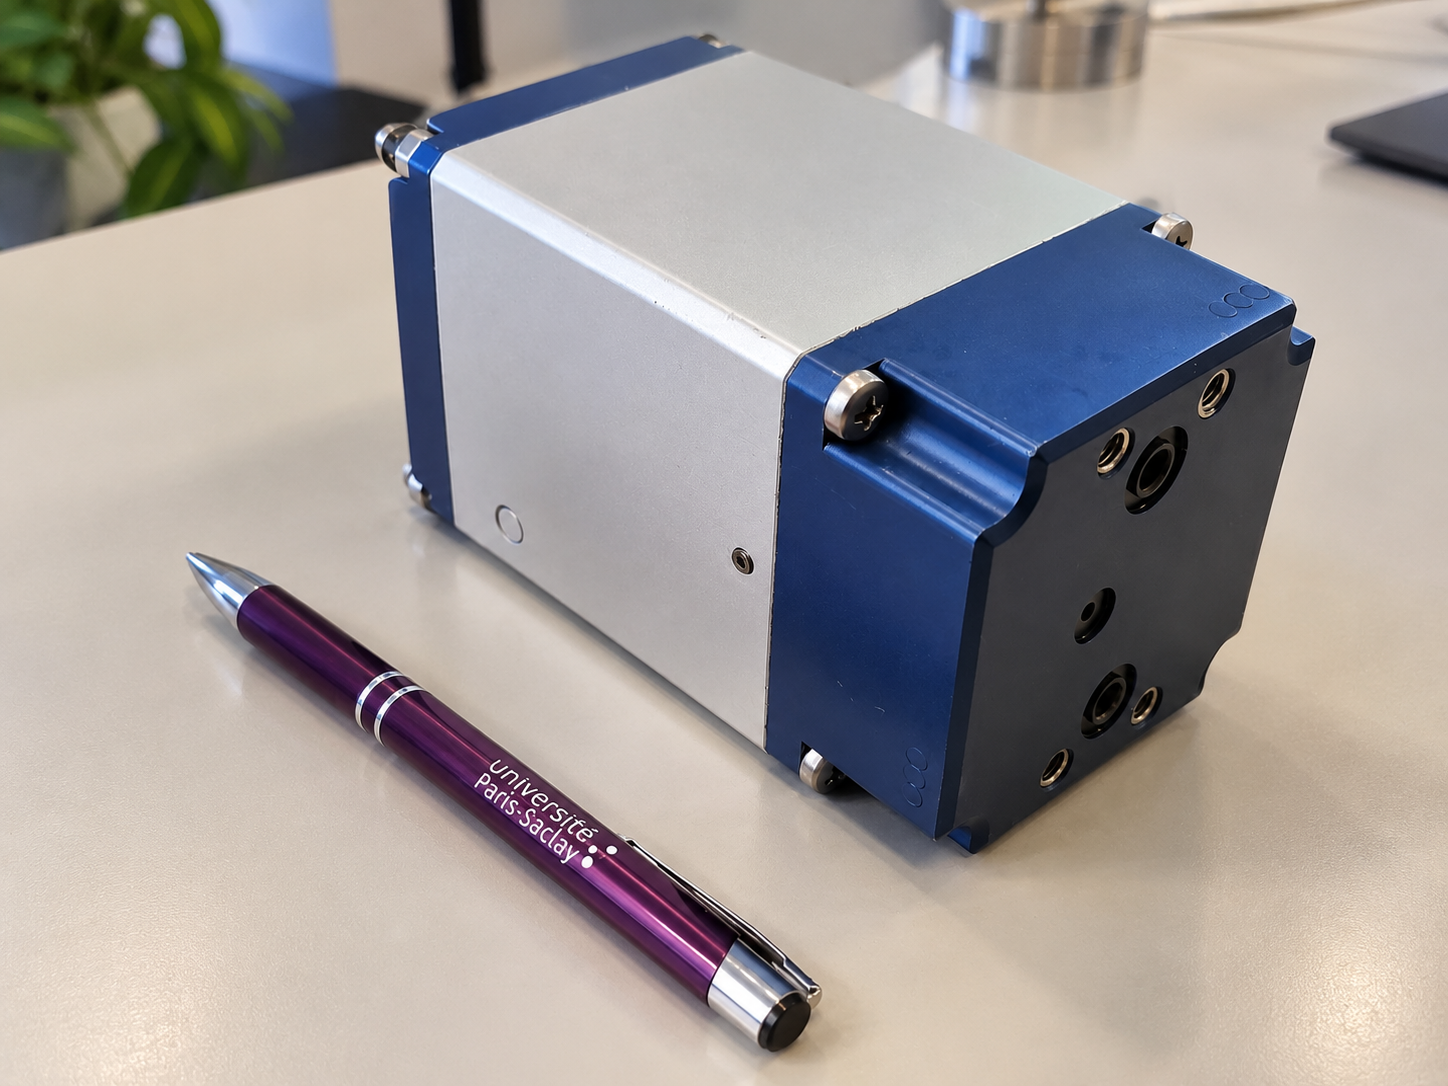
Electrohydraulic systems
A compact hydraulic power unit integrating the motor, electronics and sensors.
Explore the product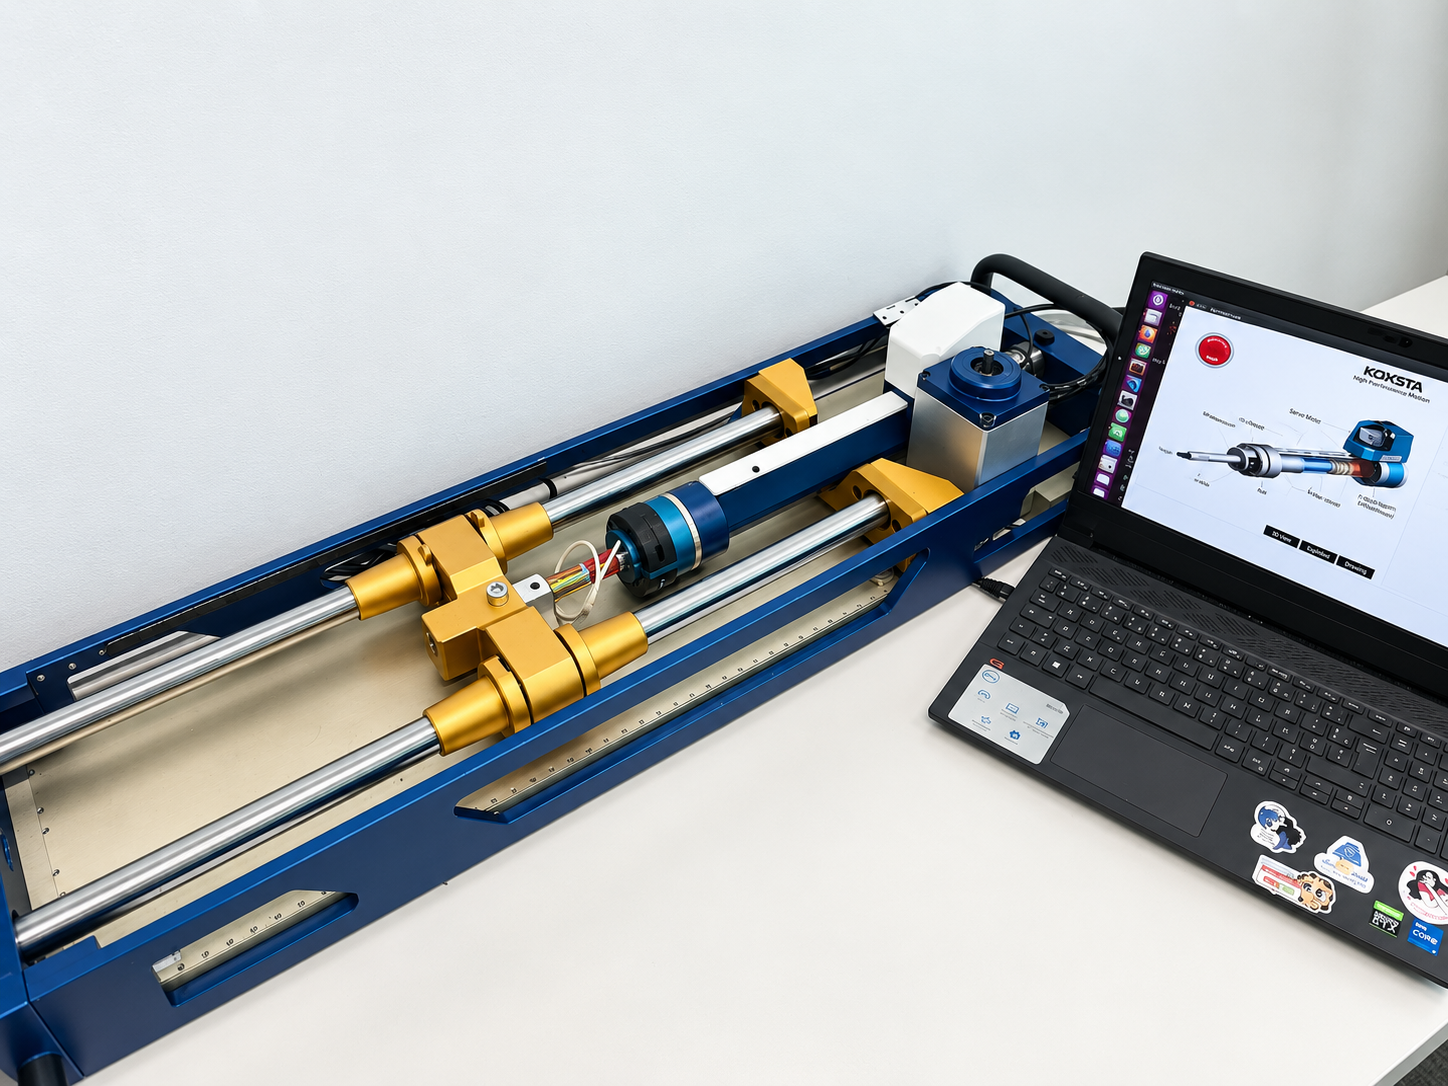
Development & prototyping
Prototype, monitor and control hybrid actuation with ROS 2, EtherCAT and MATLAB.
Explore the productWork with Kalysta
Tell us what your system needs to do. We will discuss the technology, constraints and next development steps.