Dynamic Humanoid Motion
Advanced hydraulic actuation enables fast, powerful and dynamic movements, including coordinated boxing trajectories for humanoid robotics.
Robotic platforms
Electrohydraulic humanoid research platform
Study dynamic humanoid movement on an electrohydraulically actuated platform. KD-1 reproduces the three principal boxing punches and provides a platform for robotics research, experimentation and control development.
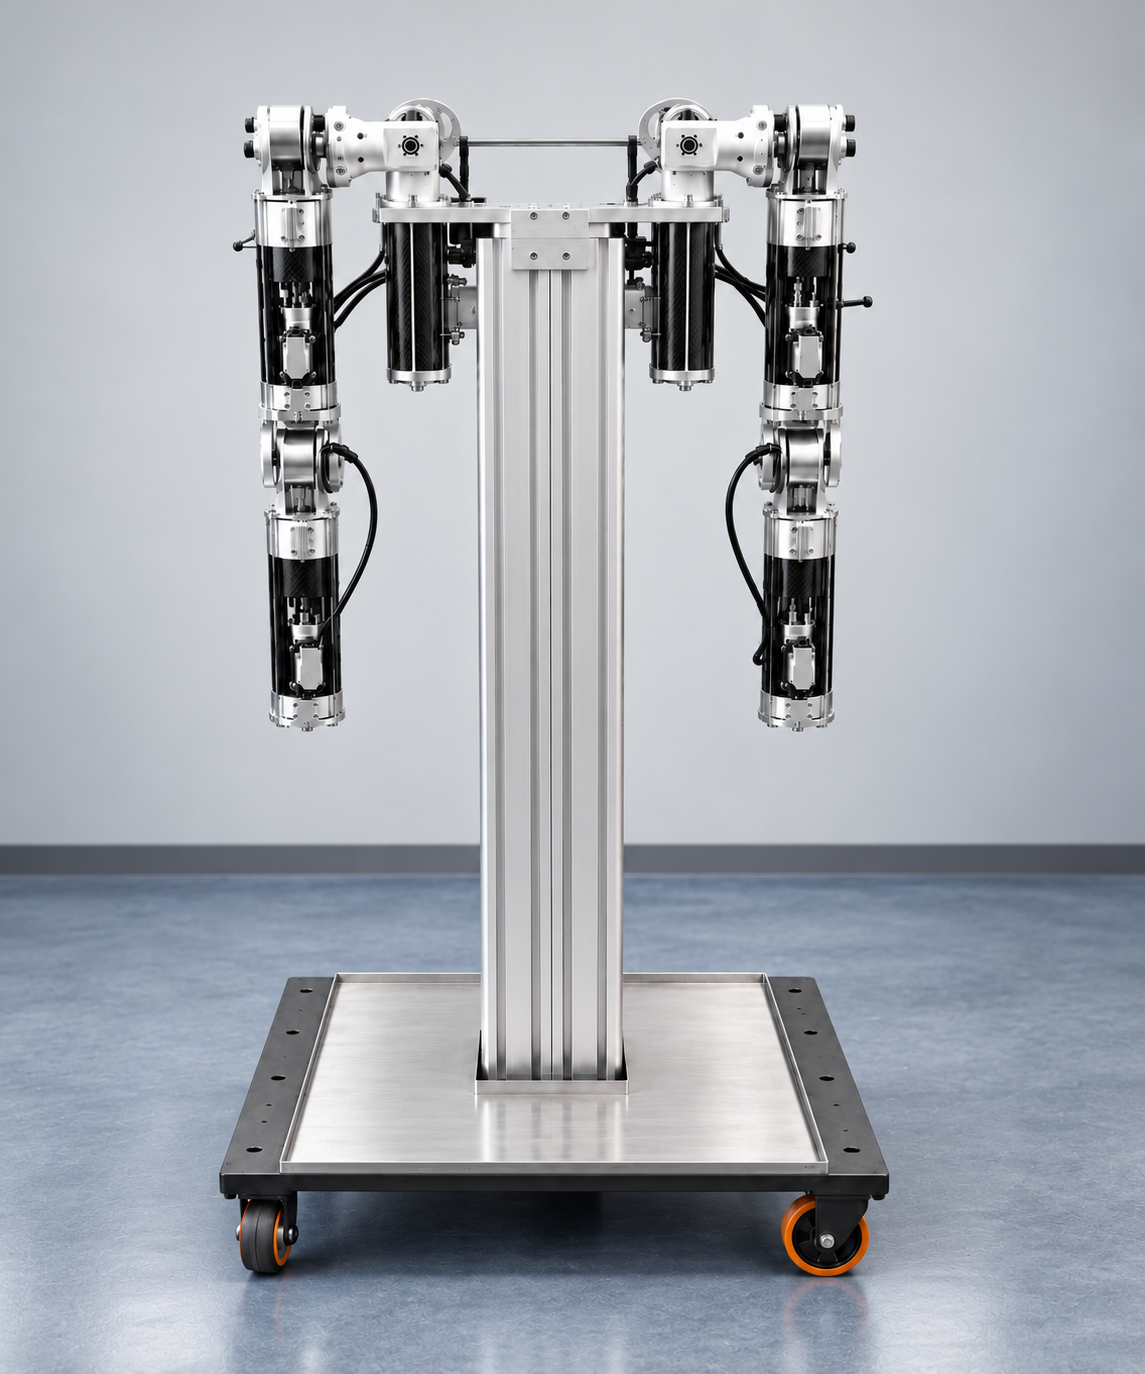
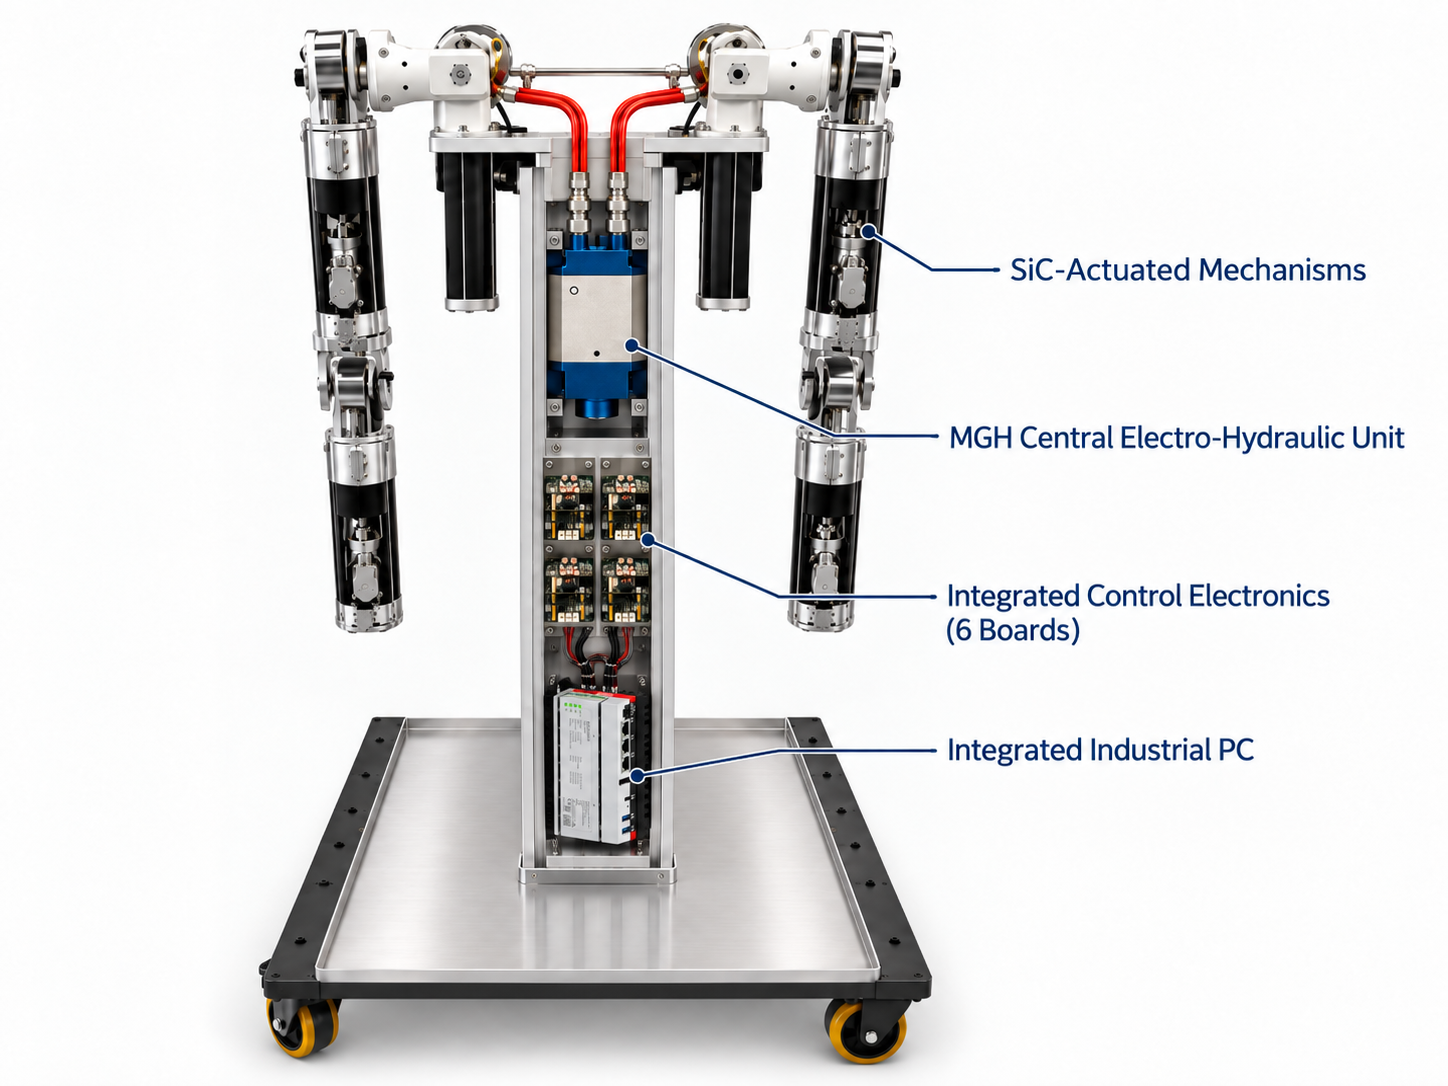
Advanced hydraulic actuation enables fast, powerful and dynamic movements, including coordinated boxing trajectories for humanoid robotics.
ROS 2 integration, high-speed EtherCAT communication and sensor feedback enable synchronized, responsive and precise motion control.
A versatile platform for developing, testing and validating advanced control strategies, dynamic motion and next-generation humanoid robotics.
KD-1 in motion
Watch the articulated arms of the electrohydraulic boxing robot in motion.
Engineered for advanced humanoid robotics research, dynamic motion studies and experimental validation. Ideal for developing and testing high-performance actuation systems, real-time control strategies and coordinated robotic movements.
Discuss Your ApplicationComplete the architecture
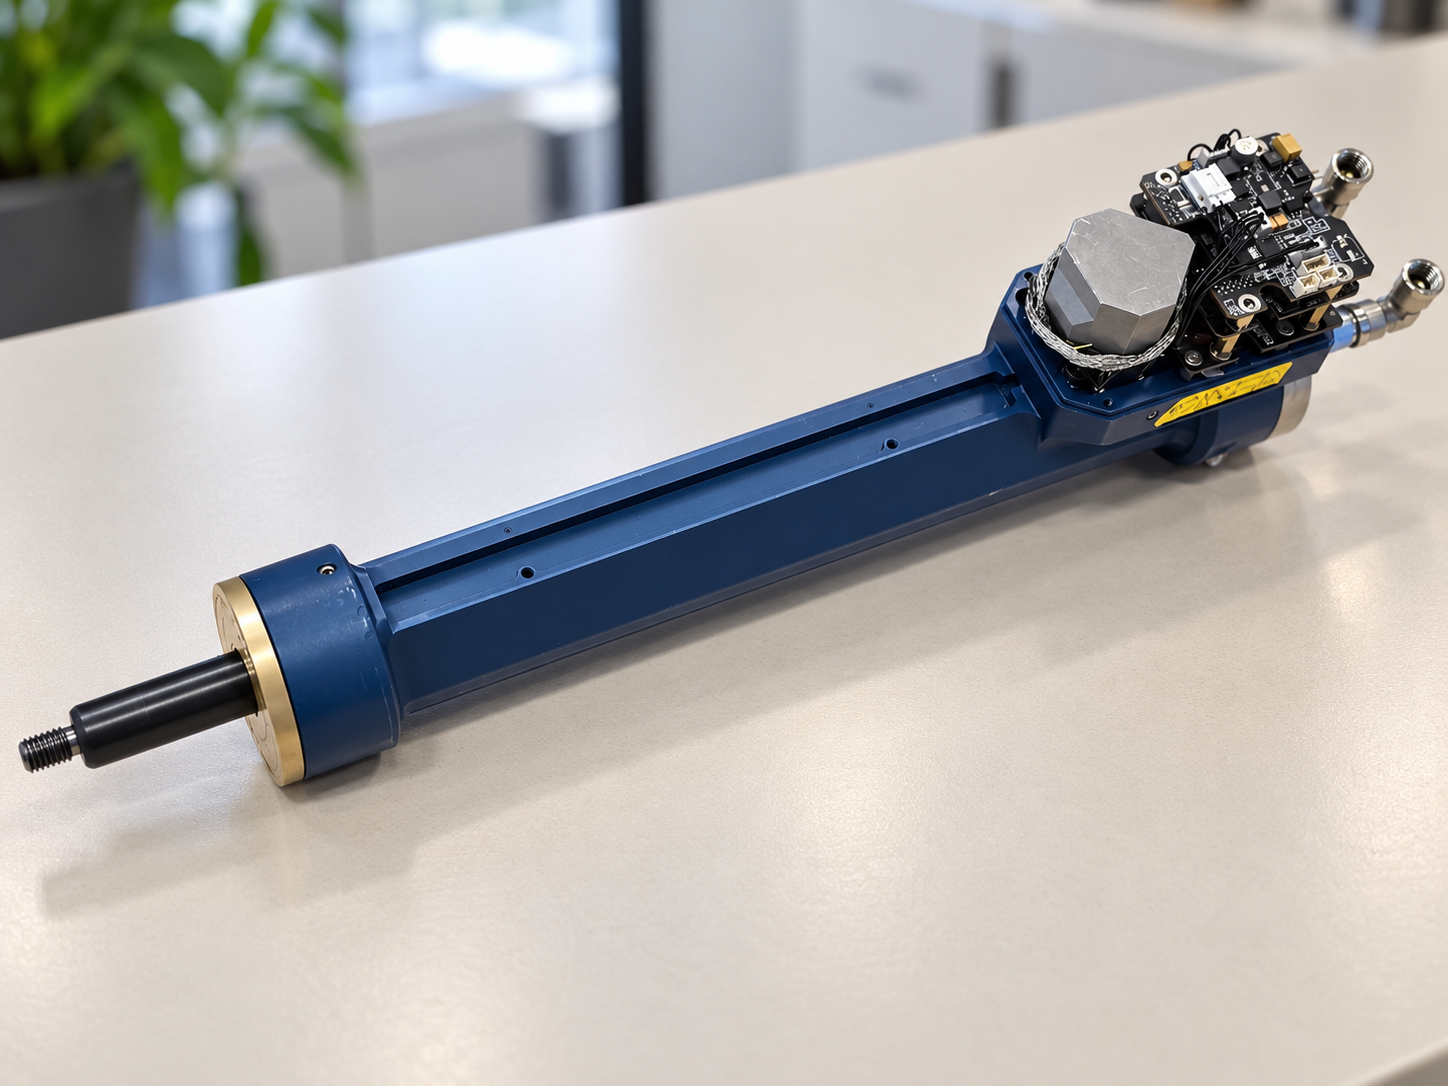
Actuators
Hydraulic force, integrated sensing and EtherCAT control in one actuator.
Explore the product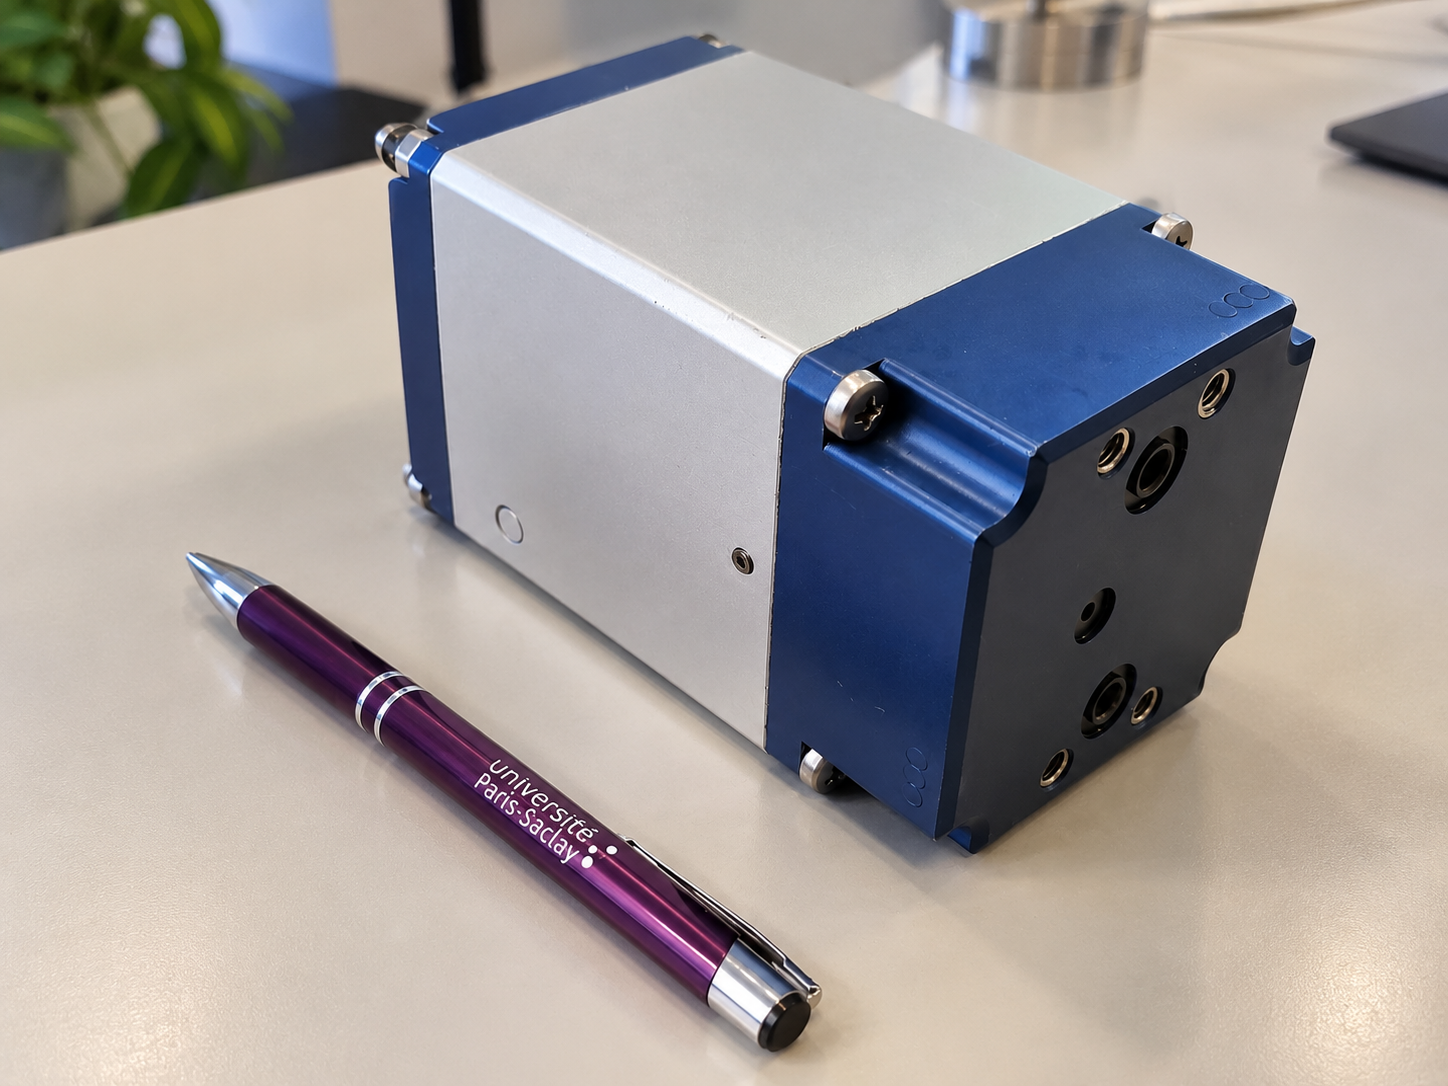
Electrohydraulic systems
A compact hydraulic power unit integrating the motor, electronics and sensors.
Explore the productWork with Kalysta
Tell us what your system needs to do. We will discuss the technology, constraints and next development steps.