Embedded Intelligence
High-performance embedded processing delivers fast, reliable real-time control for advanced actuation applications.
Electronics & control
Intelligent Embedded Control for Precision Actuation.
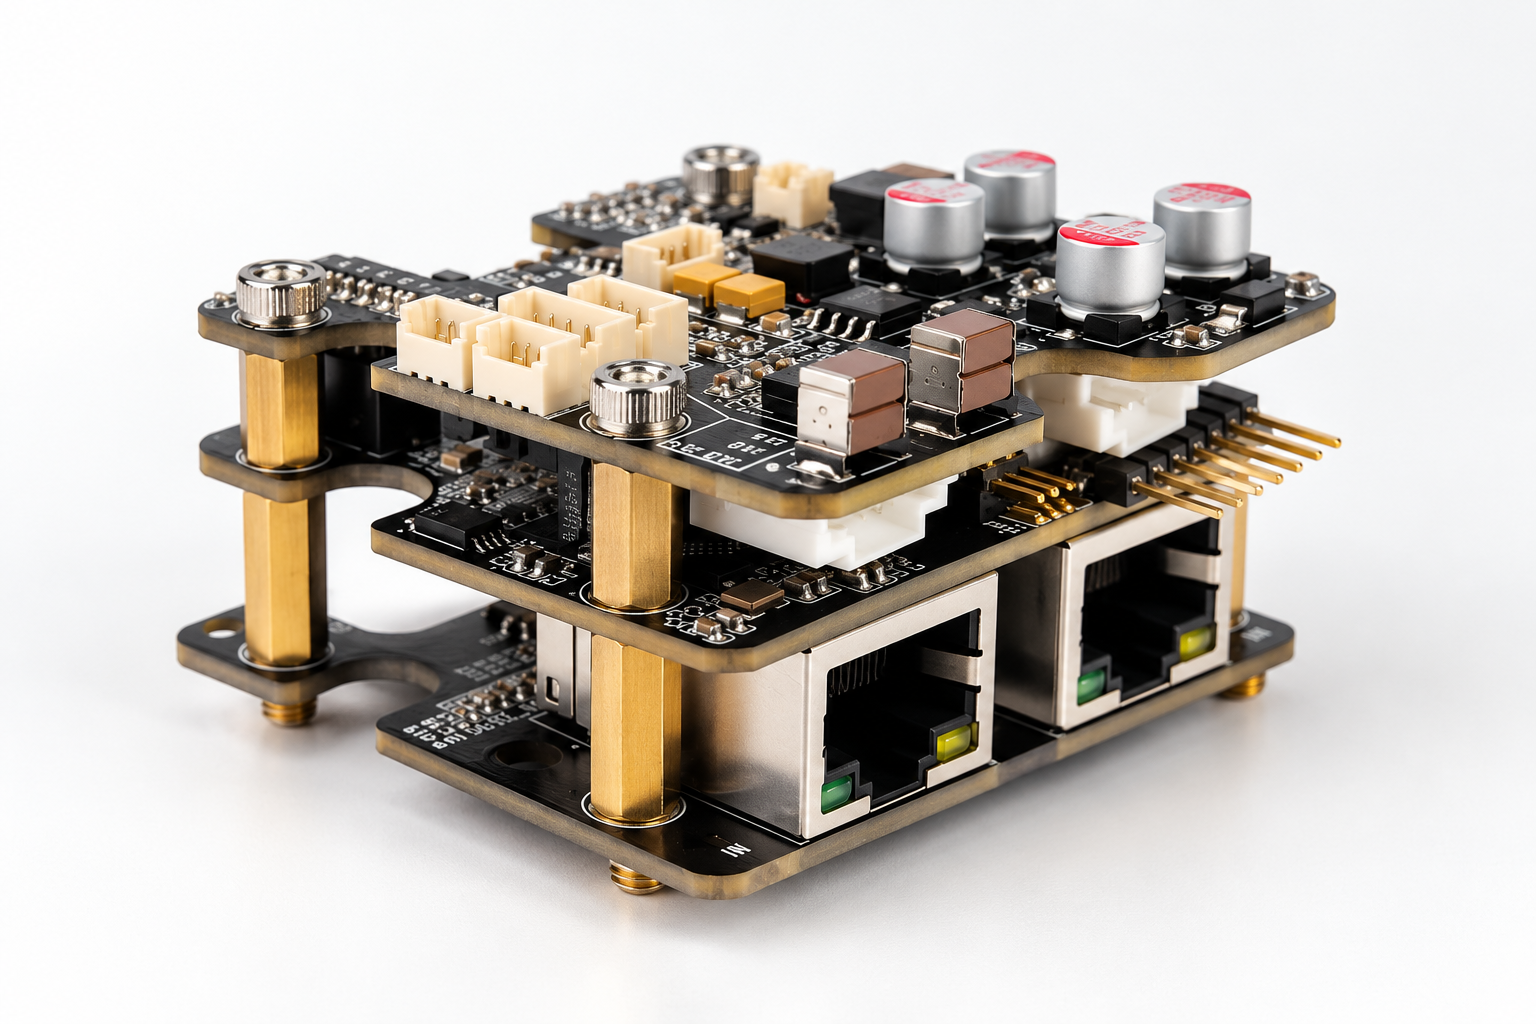
Engineered for precise, real-time hydraulic actuation, the SIC Electronic Board integrates sensor acquisition, embedded control, servovalve driving and high-speed EtherCAT communication into a compact, high-performance platform.
High-performance embedded processing delivers fast, reliable real-time control for advanced actuation applications.
Dedicated interfaces capture position, force, chamber pressures and hydraulic oil temperature for precise monitoring and control.
EtherCAT communication and ROS 2 compatibility enable smooth integration with higher-level controllers and robotic software environments.
Integrated sensing, real-time control and EtherCAT communication in one compact platform.
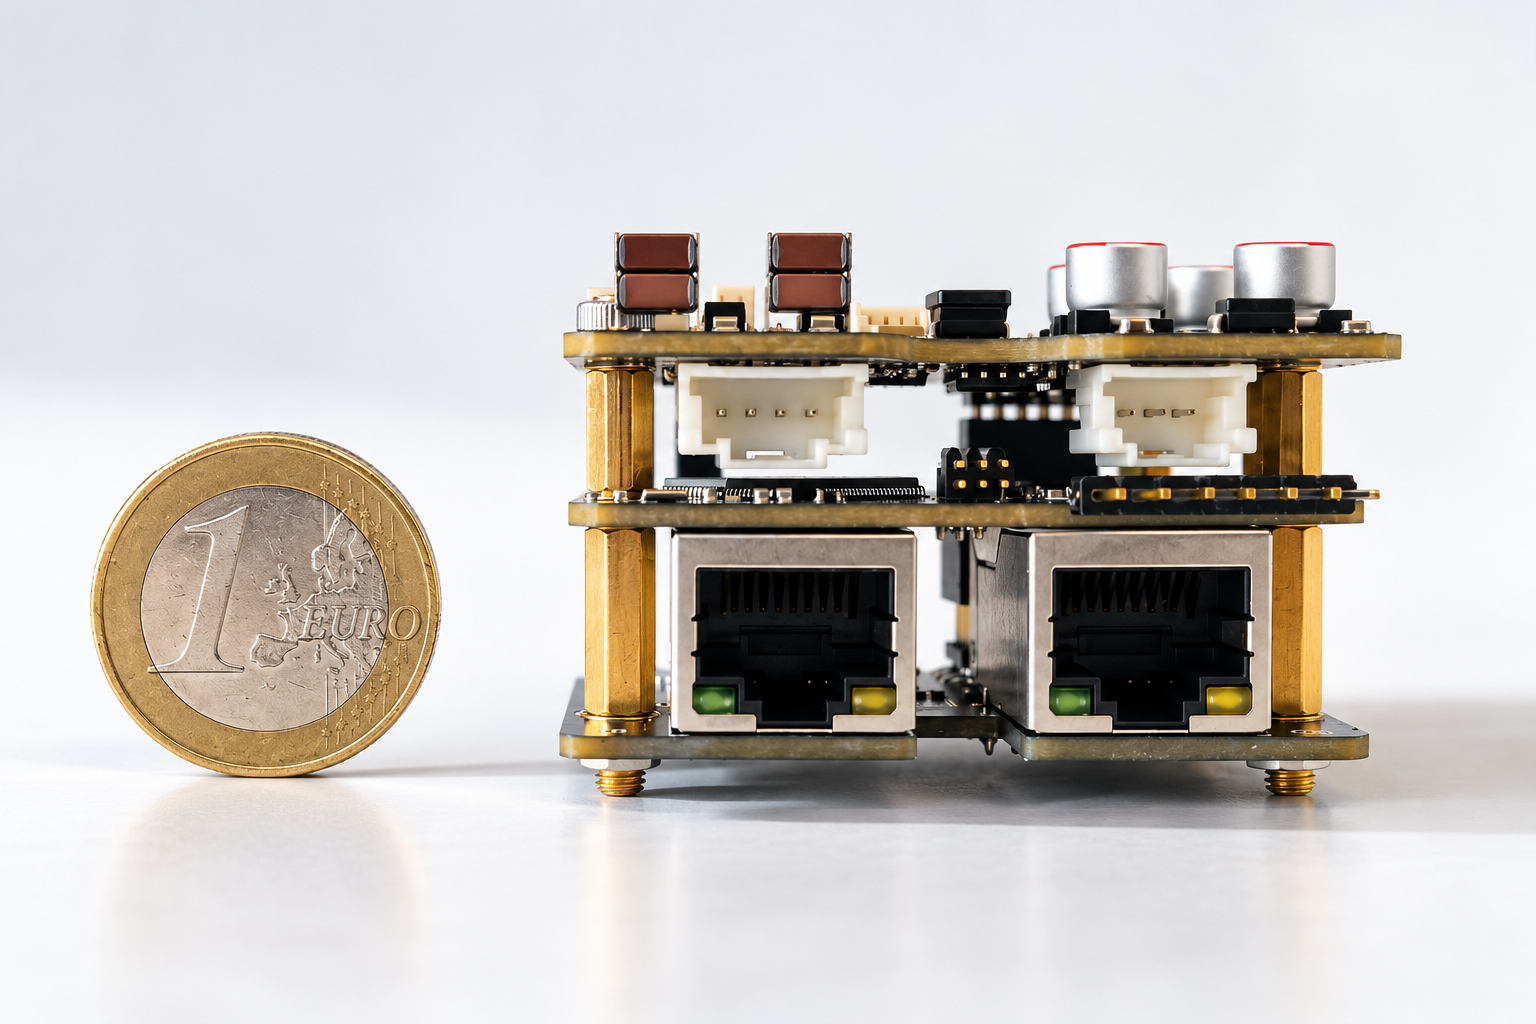
Designed to control and drive the SIC actuator, the SIC Electronic Board combines embedded processing, sensor interfacing, signal conditioning, power management, communication and servo control in a compact 48 × 48 × 28 mm platform. It integrates directly into the development kit for streamlined system integration.
Built around the STM32H743, the board delivers high-performance 32-bit Arm Cortex-M7 processing at up to 480 MHz. Its real-time acquisition architecture supports up to 16-bit ADC resolution with DMA for efficient sensor capture and deterministic control execution.
Dedicated sensor-interface and signal-conditioning circuits acquire force, position, chamber pressures and hydraulic oil temperature directly at the actuator. This integrated feedback supports precise monitoring, closed-loop control and system analysis.
Integrated power-management circuitry regulates the input supply, generates the required voltage rails for embedded electronics and sensors, and provides electrical protection. Dedicated output stages interface directly with the hydraulic servovalve for reliable actuation control.
An integrated EtherCAT slave interface enables cyclic exchange of commands and feedback with the master controller. It supports synchronized real-time operation and simplifies the integration of multiple SIC actuators within robotic and mechatronic systems.
ROS 2 compatibility enables straightforward integration with higher-level control environments for motion control, monitoring, data acquisition and advanced robotic application development.
Engineered for intelligent hydraulic actuation, distributed real-time control and advanced robotic systems. With EtherCAT communication and ROS 2 software integration, the SIC Electronic Board simplifies system development, monitoring and data acquisition.
Discuss Your ApplicationComplete the architecture
Actuators
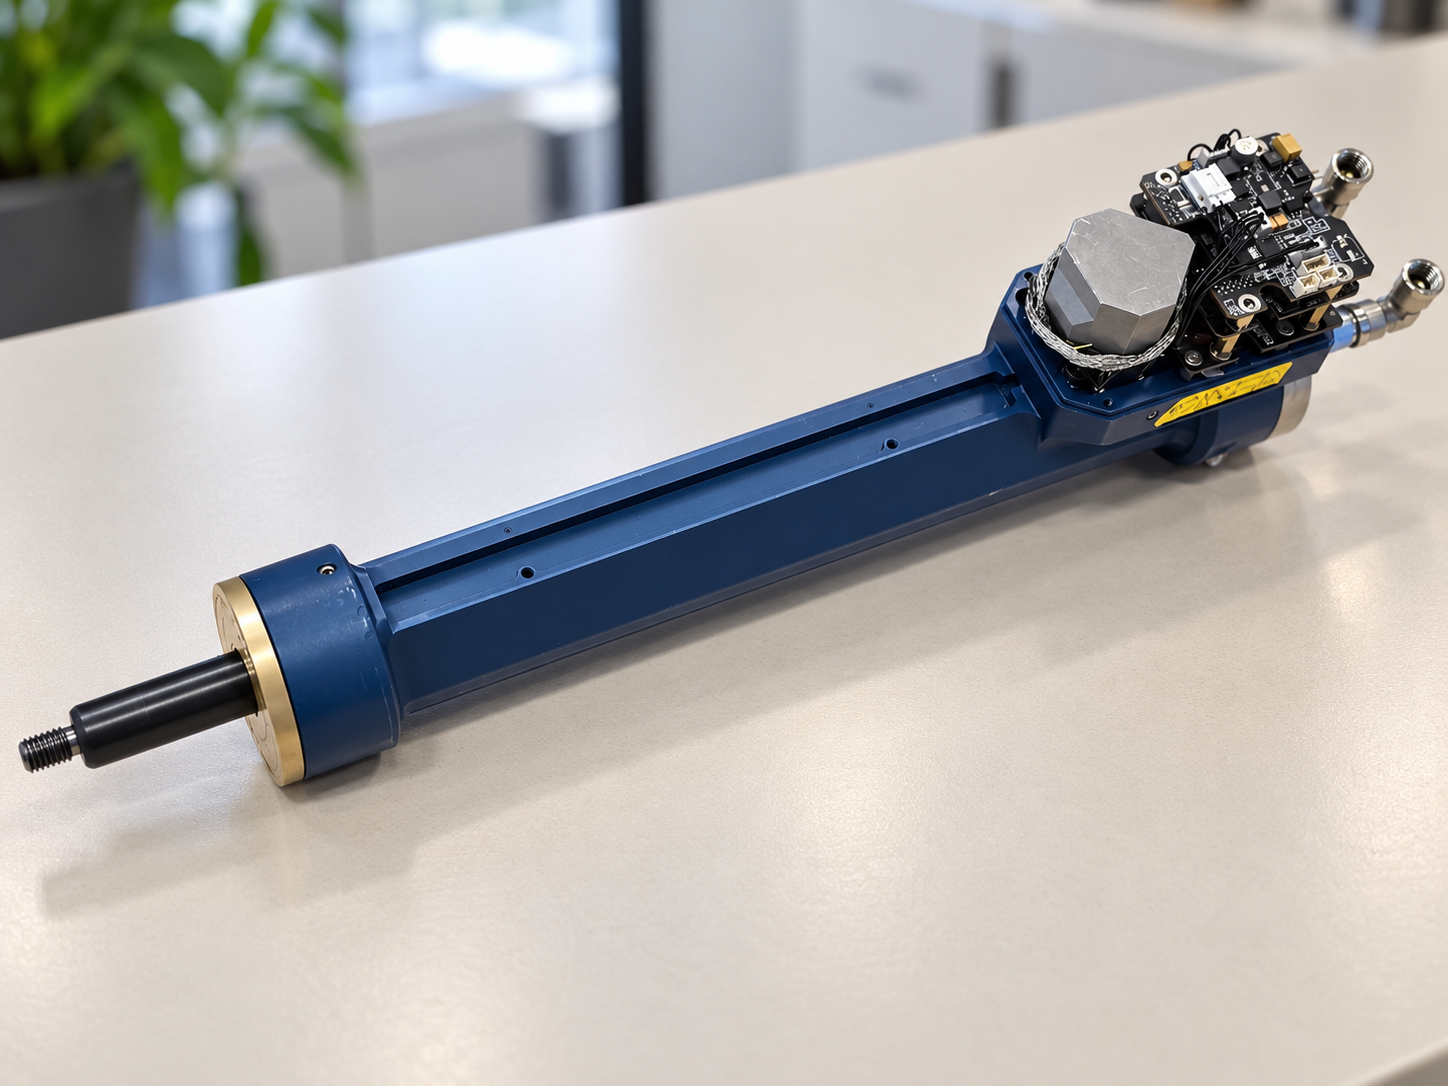
Hydraulic force, integrated sensing and EtherCAT control in one actuator.
Explore the product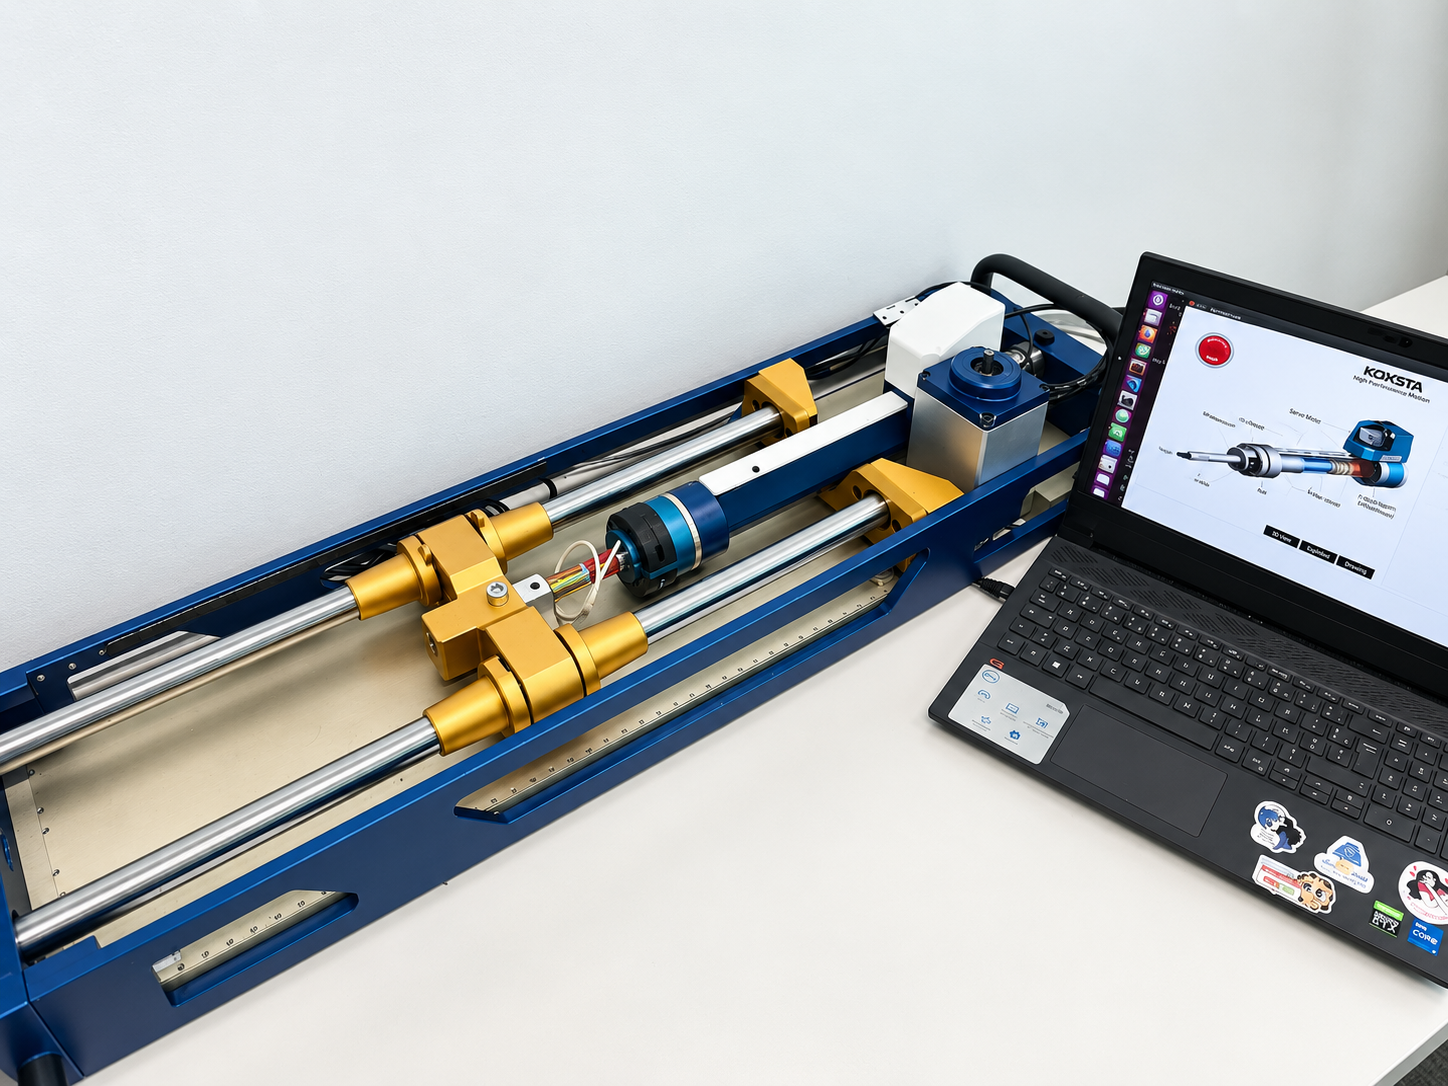
Development & prototyping
Prototype, monitor and control hybrid actuation with ROS 2, EtherCAT and MATLAB.
Explore the productWork with Kalysta
Tell us what your system needs to do. We will discuss the technology, constraints and next development steps.